-
The reason why I'm saying that the byte is received at the same time is because I tested my program with a loopback device. To be more precise I put a wire between the RxD and TxD pin of the com port. This is why I'm saying that the byte sent is received at the same time. The reason of using 5 bps is for a slow initialization of the communication between the scantool and the ECU. It's part of the ISO9141 protocol which I'm not familiar with it. I know that the ECU should reply with a sync byte (0x55) and after the speed has to be changed from 5 bps to 10400 bps. I do agree with you that my program seems to be working as intended but my problem is really the 10 seconds delay. I really don't understand it and I think this will be an issue as I go futher in my project since there will be a delay of 8 seconds (10 seconds - 2 seconds for sending the byte) between the time the ECU sends the sync byte and the time I will receive it.
thanks for your reply!
Similar Threads
-
By emc2 in forum General Support
Replies: 0
Last Post: 12-12-2009, 11:28 AM
-
By dougvega in forum Networking
Replies: 0
Last Post: 03-26-2006, 07:00 AM
-
By smitstain in forum Hardware & Booting
Replies: 4
Last Post: 06-16-2005, 09:39 PM
-
By ariels in forum Hardware & Booting
Replies: 1
Last Post: 03-15-2005, 08:44 AM
-
By thetreed1 in forum Customising & Remastering
Replies: 2
Last Post: 02-08-2004, 05:19 PM
 Posting Permissions
- You may not post new threads
- You may not post replies
- You may not post attachments
- You may not edit your posts
-
Forum Rules

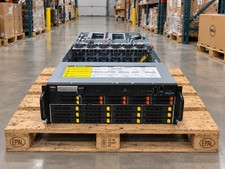
Gigabyte 4U AI Server 10x Nvidia GPU 2x Xeon Gold 6150 36 Core 2.7GHz DDR4 RAM
$1625.00
867959-B21 HPE ProLiant DL360 G10 CTO Server W/ 2x 865414-B21 1x 840140-001
$245.00
Dell PowerEdge R240 Intel Xeon E-2224 3.50GHz 8GB DDR4 ECC NO HDD 250W
$285.97
Dell PowerEdge FX2s + 8x FC430 Blades 16x E5-2630v4 160 Cores Rails No PSU/RAM
$699.00
Dell 6TB 7.2K RPM SATA 6Gb/s 512e 3.5" Enterprise PowerEdge H
$75.00
Dell PowerEdge R730XD 28 Core Server 2X Xeon E5-2680 V4 H730 32GB RAM No HDD
$378.93
Dell PowerEdge C4130 1U AI GPU Server | 2x E5-2690 v3 | 64gb Ram | 2x 1600W
$524.99

Dell PowerEdge C4130 1U AI GPU Server | 2x E5-2680 v3 | 32gb Ram | 2x 1600W
$409.99
Dell PowerEdge R530 2x E5-2630v4 H330 iDRAC8 Port Card Riser No PSU/RAM/HDD
$99.99
Dell Intel X710-DA2 5N7Y5 Dual-Port 10GbE SFP+ PCIe 3.0 x8 Network Adapter
$27.50



 Reply With Quote